Dr. Daniel Höller
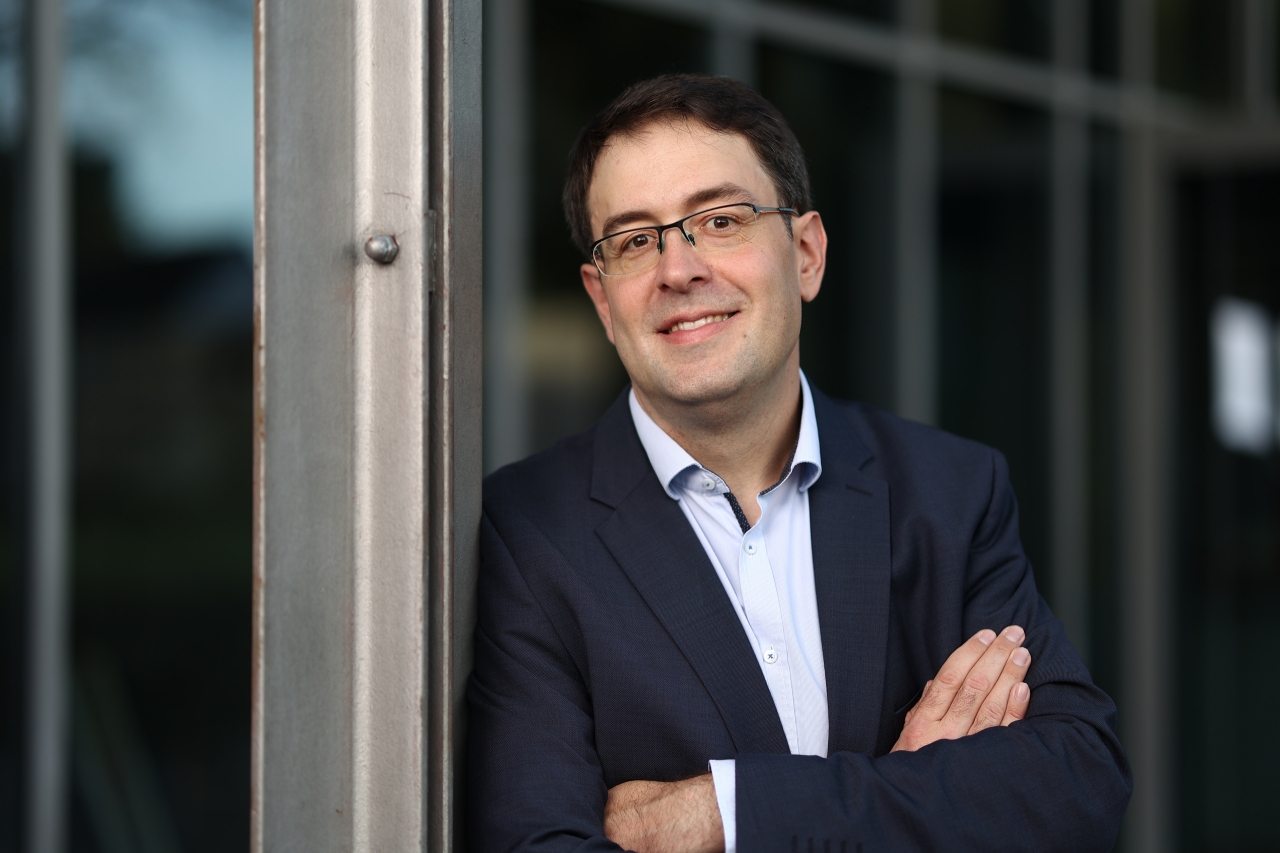 | Since June 2026, I have my own group, funded by the Deutsche Forschungsgemeinschaft (DFG, German Research Foundation) in the Emmy Noether program.
From January 2020 to June 2026, I was a postdoctoral researcher in the Foundations of Artificial Intelligence (FAI) Group, headed by Prof. Dr. Jörg Hoffmann (my alumni page is here).
Before that, I did my PhD at the Institute of Artificial Intelligence at Ulm University, supervised by Susanne Biundo (my alumni page is here). |
Research
I am interested in many practical and theoretical aspects of AI planning, in my more recent work with a focus on neuro-symbolic techniques. These are my main lines of research:
Problem Analysis and Modelling – I have studied the structural complexity of solutions for common planning formalisms. A comprehensive discussion can be found in my dissertation thesis. I have been working on modelling assistance, and on using Decision-Focused Learning in Planning.
Domain-independent Solving – My most recent work is concerned with learning heuristic functions (see AAAI'26 or PRL'26). I have been working on solvers for HTN Planning based on heuristic search, on translations to propositional logic and classical planning. If you are interested in hierarchical planning, check out our survey on the topic (IJCAI'19). I have been working on lifted classical planning, e.g. lifted heuristics, lifted landmark generation, and solvers based on a translation from lifted planning to propositional logic.
Trustworthy Decision Making – My most recent work is concerned with methods to gain trust in learned action policies, e.g. by verification (see RIPL'26) or testing (see e.g. ICAPS'22b and ICAPS'24a). Before, I have also worked on plan explanation, and on safe DeepRL.
Awards
- I was awarded the Gold Tier reviewer distinction at the International Joint Conference on Artificial Intelligence/European Conference on Artificial Intelligence (IJCAI-ECAI) in 2026.
- My dissertation thesis Hierarchical Planning – Expressivity Analysis, Solving Techniques, and Problem Compilations won the ICAPS 2024 Best Dissertation Award.
- Our paper Modeling Assistance for Hierarchical Planning: An Approach for Correcting Hierarchical Domains with Missing Actions by Songtuan Lin, Daniel Höller, and Pascal Bercher won the SoCS 2024 Best Student Paper Award.
- Winner in 4 out of 6 tracks and runner-up in 5 out of 6 tracks in the HTN tracks of the 2023 International Planning Competition (IPC). Check out the results here.
- Our paper HTN Plan Repair via Model Transformation by Daniel Höller, Pascal Bercher, Gregor Behnke, and Susanne Biundo was shortlisted for Best Paper Award (3rd place) at the 2020 German Conference on Artificial Intelligence (KI).
- Our paper A Generic Method to Guide HTN Progression Search with Classical Heuristics by Daniel Höller, Pascal Bercher, Gregor Behnke, and Susanne Biundo won the ICAPS 2018 Best Student Paper Award.
- Our paper Plan and Goal Recognition as HTN Planning by Daniel Höller, Gregor Behnke, Pascal Bercher, and Susanne Biundo won the ICTAI 2018 CV Ramamoorthy Best Paper Award.
Publications
2026
| ■ | [90] | Daniel Höller: Learning Heuristic Functions for HTN Planning. Proceedings of the 40th AAAI Conference on Artificial Intelligence (AAAI), 2026: 36262–36270 (PDF, BibTeX) |
| ■ | [89] | Marcel Schubert and Daniel Höller: Safety Verification of Additive Tree Ensemble Policies via Symbolic Search. Proceedings of the ICAPS Workshop on Reliability In Planning and Learning (RIPL), 2026 (PDF, BibTeX) |
| ■ | [88] | Magnus Cunow, Nicola J. Müller, Timo P. Gros, Gregor Behnke, and Daniel Höller: An Admissible Neuro-Symbolic Landmark Cut Heuristic – Preliminary Results. Proceedings of the ICAPS Workshop on Bridging the Gap Between AI Planning and Reinforcement Learning (PRL), 2026 (PDF, BibTeX) |
2025
| ■ | [87] | Pascal Lauer, Álvaro Torralba, Daniel Höller, and Jörg Hoffmann: Continuing the Quest for Polynomial Time Heuristics in PDDL Input Size: Tractable Cases for Lifted h-Add. Proceedings of the 35th International Conference on Automated Planning and Scheduling (ICAPS), 2025: 74–83 (PDF, BibTeX) |
| ■ | [86] | Daniel Höller: Learning Heuristic Functions for HTN Planning. Proceedings of the ICAPS Workshop on Bridging the Gap Between AI Planning and Reinforcement Learning (PRL), 2025 (PDF, BibTeX) |
2024
| ■ | [85] | Daniel Höller: The TOAD System for Totally Ordered HTN Planning. Journal of Artificial Intelligence Research (JAIR) 80: 613–663 (2024) (PDF, BibTeX) |
| ■ | [84] | Jayanta Mandi, Marco Foschini, Daniel Höller, Sylvie Thiébaux, Jörg Hoffmann, and Tias Guns: Decision-Focused Learning to Predict Action Costs for Planning. Proceedings of the 27th European Conference on Artificial Intelligence (ECAI), 2024: 4060–4067 (PDF, BibTeX) |
| ■ | [83] | Songtuan Lin, Daniel Höller, and Pascal Bercher: Modeling Assistance for Hierarchical Planning: An Approach for Correcting Hierarchical Domains with Missing Actions. Proceedings of the 17th International Symposium on Combinatorial Search (SoCS), 2024: 55–63, Best Student Paper Award (PDF, BibTeX) |
| ■ | [82] | Jan Eisenhut, Xandra Schuler, Daniel Fišer, Daniel Höller, Maria Christakis, and Jörg Hoffmann: New Fuzzing Biases for Action Policy Testing. Proceedings of the 34th International Conference on Automated Planning and Scheduling (ICAPS), 2024: 162–167 (PDF, BibTeX) |
| ■ | [81] | Marcel Steinmetz, Sylvie Thiébaux, Daniel Höller, and Florent Teichteil-Königsbuch: Explaining the Space of SSP Policies via Policy-Property Dependencies: Complexity, Algorithms, and Relation to Multi-Objective Planning. Proceedings of the 34th International Conference on Automated Planning and Scheduling (ICAPS), 2024: 555–564 (PDF, BibTeX) |
| ■ | [80] | Timo P. Gros, Nicola J. Müller, Daniel Höller, and Verena Wolf: Safe Reinforcement Learning Through Regret and State Restorations in Evaluation Stages. Principles of Verification: Cycling the Probabilistic Landscape 2024: 18–38 (PDF, BibTeX) |
| ■ | [79] | Timo P. Gros, Nicola J. Müller, Daniel Höller, and Verena Wolf: Safe Reinforcement Learning Through Regret and State Restorations in Evaluation Stages. Proceedings of the ICAPS workshop on Reliable Data-Driven Planning and Scheduling (RDDPS), 2024 (PDF, BibTeX) |
| ■ | [78] | Marcel Schubert, Julia Wichlacz, and Daniel Höller: Reasonable Landmark Orderings for Lifted Classical Planning. Proceedings of the ICAPS workshop on Heuristics and Search for Domain-Independent Planning (HSDIP), 2024 (PDF, BibTeX) |
| ■ | [77] | Pascal Lauer, Álvaro Torralba, Daniel Höller, and Jörg Hoffmann: A Lifted Backward Computation of h-Add. Proceedings of the ICAPS workshop on Heuristics and Search for Domain-Independent Planning (HSDIP), 2024 (PDF, BibTeX) |
2023
| ■ | [76] | Daniel Höller: Hierarchical Planning – Expressivity Analysis, Solving Techniques, and Problem Compilations. Dissertation Thesis, Ulm University, 2023, ICAPS Best Dissertation Award 2024 (PDF, BibTeX) |
| ■ | [75] | Timo P. Gros, Joschka Groß, Daniel Höller, Jörg Hoffmann, Michaela Klauck, Hendrik Meerkamp, Nicola J. Müller, Lukas Schaller, and Verena Wolf: DSMC Evaluation Stages: Fostering Robust and Safe Behavior in Deep Reinforcement Learning – Extended Version. ACM Transactions on Modeling and Computer Simulation (2023) (PDF, BibTeX) |
| ■ | [74] | Julia Wichlacz, Daniel Höller, Daniel Fišer, and Jörg Hoffmann: A Landmark-Cut Heuristic for Lifted Optimal Planning. Proceedings of the 26th European Conference on Artificial Intelligence (ECAI), 2023: 2623–2630 (PDF, BibTeX) |
| ■ | [73] | Pascal Bercher, Daniel Höller, Julia Wichlacz, and Susanne Biundo: Proceedings of the 6th ICAPS Workshop on Hierarchical Planning. 2023 (PDF, BibTeX) |
| ■ | [72] | Daniel Höller: The TOAD System for Totally Ordered HTN Planning in the 2023 IPC. Proceedings of the International Planning Competition (IPC) – Planner Description Papers, 2023 (PDF, BibTeX) |
| ■ | [71] | Daniel Höller: The PANDA λ System for HTN Planning in the 2023 IPC. Proceedings of the International Planning Competition (IPC) – Planner Description Papers, 2023 (PDF, BibTeX) |
| ■ | [70] | Daniel Höller: The PANDA Progression System for HTN Planning in the 2023 IPC. Proceedings of the International Planning Competition (IPC) – Planner Description Papers, 2023 (PDF, BibTeX) |
| ■ | [69] | Conny Olz, Daniel Höller, and Pascal Bercher: The PandaDealer System for Totally Ordered HTN Planning in the 2023 IPC. Proceedings of the International Planning Competition (IPC) – Planner Description Papers, 2023 (PDF, BibTeX) |
| ■ | [68] | Xandra Schuler, Jan Eisenhut, Daniel Höller, Daniel Fišer, and Jörg Hoffmann: Action Policy Testing with Heuristic-Based Bias Functions. Proceedings of the 2nd ICAPS Workshop on Reliable Data-Driven Planning and Scheduling (RDDPS), 2023 (PDF, BibTeX) |
2022
| ■ | [67] | Gregor Behnke, Florian Pollitt, Daniel Höller, Pascal Bercher, and Ron Alford: Making Translations to Classical Planning Competitive with Other HTN Planners. Proceedings of the 36th AAAI Conference on Artificial Intelligence (AAAI), 2022: 9687–9697 (PDF, BibTeX) |
| ■ | [66] | Daniel Höller and Gregor Behnke: Encoding Lifted Classical Planning in Propositional Logic. Proceedings of the 32nd International Conference on Automated Planning and Scheduling (ICAPS), 2022: 134–144 (PDF, BibTeX) |
| ■ | [65] | Daniel Höller, Julia Wichlacz, Pascal Bercher, and Gregor Behnke: Compiling HTN Plan Verification Problems into HTN Planning Problems. Proceedings of the 32nd International Conference on Automated Planning and Scheduling (ICAPS), 2022: 145–150 (PDF, BibTeX) |
| ■ | [64] | Marcel Steinmetz, Daniel Fišer, Hasan Ferit Eniser, Patrick Ferber, Timo P. Gros, Philippe Heim, Daniel Höller, Xandra Schuler, Valentin Wüstholz, Maria Christakis, and Jörg Hoffmann: Debugging a Policy: Automatic Action-Policy Testing in AI Planning. Proceedings of the 32nd International Conference on Automated Planning and Scheduling (ICAPS), 2022: 353–361 (PDF, BibTeX) |
| ■ | [63] | Julia Wichlacz, Daniel Höller, and Jörg Hoffmann: Landmark Heuristics for Lifted Classical Planning. Proceedings of the 31st International Joint Conference on Artificial Intelligence (IJCAI), 2022: 4665–4671 (PDF, BibTeX) |
2021
| ■ | [62] | Pascal Bercher, Daniel Höller, Gregor Behnke, Susanne Biundo, Vikas Shivashankar, and Ron Alford: Report on the First and Second Workshops on Hierarchical Planning Held at the International Conference on Automated Planning and Scheduling. AI Magazine 42: 83–85 (2021) (PDF, BibTeX) |
| ■ | [61] | Daniel Höller, Gregor Behnke, Pascal Bercher, and Susanne Biundo: The PANDA Framework for Hierarchical Planning. Künstliche Intelligenz 35: 391–396 (2021) (PDF, BibTeX) |
| ■ | [60] | Daniel Höller and Pascal Bercher: Landmark Generation in HTN Planning. Proceedings of the 35th AAAI Conference on Artificial Intelligence (AAAI), 2021: 11826–11834 (PDF, BibTeX) |
| ■ | [59] | Daniel Höller: Translating Totally Ordered HTN Planning Problems to Classical Planning Problems Using Regular Approximation of Context-Free Languages. Proceedings of the 31st International Conference on Automated Planning and Scheduling (ICAPS), 2021: 159–167 (PDF, BibTeX) |
| ■ | [58] | Daniel Höller and Gregor Behnke: Loop Detection in the PANDA Planning System. Proceedings of the 31st International Conference on Automated Planning and Scheduling (ICAPS), 2021: 168–173 (PDF, BibTeX) |
| ■ | [57] | Pascal Lauer, Álvaro Torralba, Daniel Fišer, Daniel Höller, Julia Wichlacz, and Jörg Hoffmann: Polynomial-Time in PDDL Input Size: Making the Delete Relaxation Feasible for Lifted Planning. Proceedings of the 30th International Joint Conference on Artificial Intelligence (IJCAI), 2021: 4119–4126 (PDF, BibTeX) |
| ■ | [56] | Timo P. Gros, Daniel Höller, Jörg Hoffmann, Michaela Klauck, Hendrik Meerkamp, and Verena Wolf: DSMC Evaluation Stages: Fostering Robust and Safe Behavior in Deep Reinforcement Learning. Proceedings of the 18th International Conference on Quantitative Evaluation of SysTems (QEST), 2021: 197–216 (BibTeX) |
| ■ | [55] | Julia Wichlacz, Daniel Höller, and Jörg Hoffmann: Landmark Heuristics for Lifted Planning – Extended Abstract. Proceedings of the 14th International Symposium on Combinatorial Search (SoCS), 2021: 242–244 (PDF, BibTeX) |
| ■ | [54] | Gregor Behnke, Daniel Höller, and Pascal Bercher: Proceedings of the ICAPS Workshop on the International Planning Competition. 2021 (PDF, BibTeX) |
| ■ | [53] | Daniel Höller, Songtuan Lin, Kutluhan Erol, and Pascal Bercher: From PCP to HTN Planning Through CFGs. Proceedings of the 10th International Planning Competition – Planner and Domains Abstracts (IPC), 2021 (PDF, BibTeX) |
| ■ | [52] | Daniel Höller, Julia Wichlacz, Pascal Bercher, and Gregor Behnke: Compiling HTN Plan Verification Problems into HTN Planning Problems. Proceedings of the 4th ICAPS Workshop on Hierarchical Planning (HPlan), 2021 (PDF, BibTeX) |
| ■ | [51] | Pascal Lauer, Álvaro Torralba, Daniel Fišer, Daniel Höller, Julia Wichlacz, and Jörg Hoffmann: Polynomial-Time in PDDL Input Size: Making the Delete Relaxation Feasible for Lifted Planning. Proceedings of the ICAPS Workshop on Heuristics and Search for Domain-Independent Planning (HSDIP), 2021 (PDF, BibTeX) |
| ■ | [50] | Marcel Steinmetz, Timo P. Gros, Philippe Heim, Daniel Höller, and Jörg Hoffmann: Debugging a Policy: A Framework for Automatic Action Policy Testing. Proceedings of the ICAPS Workshop on Bridging the Gap Between AI Planning and Reinforcement Learning (PRL), 2021 (PDF, BibTeX) |
2020
| ■ | [49] | Daniel Höller, Pascal Bercher, Gregor Behnke, and Susanne Biundo: HTN Planning as Heuristic Progression Search. Journal of Artificial Intelligence Research (JAIR) 67: 835–880 (2020) (PDF, BibTeX) |
| ■ | [48] | Gregor Behnke, Daniel Höller, Alexander Schmid, Pascal Bercher, and Susanne Biundo: On Succinct Groundings of HTN Planning Problems. Proceedings of the 34th AAAI Conference on Artificial Intelligence (AAAI), 2020: 9775–9784 (PDF, BibTeX) |
| ■ | [47] | Daniel Höller, Gregor Behnke, Pascal Bercher, Susanne Biundo, Humbert Fiorino, Damien Pellier, and Ron Alford: HDDL: An Extension to PDDL for Expressing Hierarchical Planning Problems. Proceedings of the 34th AAAI Conference on Artificial Intelligence (AAAI), 2020: 9883–9891 (PDF, BibTeX) |
| ■ | [46] | Arne Köhn, Julia Wichlacz, Álvaro Torralba, Daniel Höller, Jörg Hoffmann, and Alexander Koller: Generating Instructions at Different Levels of Abstraction. Proceedings of the 28th International Conference on Computational Linguistics (COLING), 2020: 2802–2813 (PDF, BibTeX) |
| ■ | [45] | Daniel Höller, Pascal Bercher, and Gregor Behnke: Delete- and Ordering-Relaxation Heuristics for HTN Planning. Proceedings of the 29th International Joint Conference on Artificial Intelligence (IJCAI), 2020: 4076–4083 (PDF, BibTeX) |
| ■ | [44] | Daniel Höller, Pascal Bercher, Gregor Behnke, and Susanne Biundo: HTN Plan Repair via Model Transformation. Proceedings of the 43rd German Conference on AI (KI), 2020: 88–101 (PDF, BibTeX) |
| ■ | [43] | Timo P. Gros, Daniel Höller, Jörg Hoffmann, and Verena Wolf: Tracking the Race Between Deep Reinforcement Learning and Imitation Learning. Proceedings of the 17th International Conference on Quantitative Evaluation of SysTems (QEST), 2020: 11–17 (PDF, BibTeX) |
| ■ | [42] | Julia Wichlacz, Daniel Höller, Álvaro Torralba, and Jörg Hoffmann: Applying Monte-Carlo Tree Search in HTN Planning. Proceedings of the 13th International Symposium on Combinatorial Search (SoCS), 2020: 82–90 (PDF, BibTeX) |
| ■ | [41] | Pascal Bercher, Daniel Höller, Roman Barták, and Susanne Biundo: Proceedings of the 3rd ICAPS Workshop on Hierarchical Planning. 2020 (PDF, BibTeX) |
| ■ | [40] | Gregor Behnke, Daniel Höller, and Pascal Bercher: Proceedings of the 10th International Planning Competition: Planner and Domain Abstracts. 2020 (PDF, BibTeX) |
| ■ | [39] | Daniel Höller and Pascal Bercher: Landmark Extraction in HTN Planning. Proceedings of the 3rd ICAPS Workshop on Hierarchical Planning (HPlan), 2020 (PDF, BibTeX) |
| ■ | [38] | Daniel Höller, Pascal Bercher, and Gregor Behnke: Delete- and Ordering-Relaxation Heuristics for HTN Planning. Proceedings of the 3rd ICAPS Workshop on Hierarchical Planning (HPlan), 2020 (BibTeX) |
| ■ | [37] | Julia Wichlacz, Daniel Höller, Álvaro Torralba, and Jörg Hoffmann: Applying Monte-Carlo Tree Search in HTN Planning. Proceedings of the 3rd ICAPS Workshop on Hierarchical Planning (HPlan), 2020 (BibTeX) |
2019
| ■ | [36] | Daniel Höller, Pascal Bercher, Gregor Behnke, and Susanne Biundo: On Guiding Search in HTN Planning with Classical Planning Heuristics. Proceedings of the 28th International Joint Conference on Artificial Intelligence (IJCAI), 2019: 6171–6175 (PDF, BibTeX) |
| ■ | [35] | Pascal Bercher, Ron Alford, and Daniel Höller: A Survey on Hierarchical Planning – One Abstract Idea, Many Concrete Realizations. Proceedings of the 28th International Joint Conference on Artificial Intelligence (IJCAI), 2019: 6267–6275 (PDF, BibTeX) |
| ■ | [34] | Gregor Behnke, Daniel Höller, and Susanne Biundo: Finding Optimal Solutions in HTN Planning – A SAT-based Approach. Proceedings of the 28th International Joint Conference on Artificial Intelligence (IJCAI), 2019: 5500–5508 (PDF, BibTeX) |
| ■ | [33] | Gregor Behnke, Daniel Höller, and Susanne Biundo: Bringing Order to Chaos – A Compact Representation of Partial Order in SAT-based HTN Planning. Proceedings of the 33rd AAAI Conference on Artificial Intelligence (AAAI), 2019: 7520–7529 (PDF, BibTeX) |
| ■ | [32] | Gregor Behnke, Daniel Höller, Pascal Bercher, and Susanne Biundo: More Succinct Grounding of HTN Planning Problems – Preliminary Results. Proceedings of the 2nd ICAPS Workshop on Hierarchical Planning (HPlan), 2019 (PDF, BibTeX) |
| ■ | [31] | Daniel Höller, Gregor Behnke, Pascal Bercher, Susanne Biundo, Humbert Fiorino, Damien Pellier, and Ron Alford: HDDL – A Language to Describe Hierarchical Planning Problems. Proceedings of the 2nd ICAPS Workshop on Hierarchical Planning (HPlan), 2019 (PDF, BibTeX) |
| ■ | [30] | Gregor Behnke, Daniel Höller, Pascal Bercher, Susanne Biundo, Damien Pellier, Humbert Fiorino, and Ron Alford: Hierarchical Planning in the IPC. Proceedings of the Workshop on the International Planning Competition (WIPC), 2019 (PDF, BibTeX) |
2018
| ■ | [29] | Gregor Behnke, Daniel Höller, and Susanne Biundo: Tracking Branches in Trees – A Propositional Encoding for Solving Partially-Ordered HTN Planning Problems. Proceedings of the 30th IEEE International Conference on Tools with Artificial Intelligence (ICTAI), 2018: 73–80 (PDF, BibTeX) |
| ■ | [28] | Daniel Höller, Pascal Bercher, Gregor Behnke, and Susanne Biundo: A Generic Method to Guide HTN Progression Search with Classical Heuristics. Proceedings of the 28th International Conference on Automated Planning and Scheduling (ICAPS), 2018: 114–122, Best Student Paper Award (PDF, BibTeX) |
| ■ | [27] | Gregor Behnke, Daniel Höller, and Susanne Biundo: totSAT – Totally-Ordered Hierarchical Planning through SAT. Proceedings of the 32nd AAAI Conference on Artificial Intelligence (AAAI), 2018: 6110–6118 (PDF, BibTeX) |
| ■ | [26] | Daniel Höller, Gregor Behnke, Pascal Bercher, and Susanne Biundo: Plan and Goal Recognition as HTN Planning. Proceedings of the 30th IEEE International Conference on Tools with Artificial Intelligence (ICTAI), 2018: 466–473, Best Paper Award (PDF, BibTeX) |
| ■ | [25] | Benedikt Leichtmann, Pascal Bercher, Daniel Höller, Gregor Behnke, Susanne Biundo, Verena Nitsch, and Martin Baumann: Towards a Companion System Incorporating Human Planning Behavior – A Qualitative Analysis of Human Strategies. Proceedings of the 3rd Transdisciplinary Conference on Support Technologies (TCST), 2018, Best Paper Award (PDF, BibTeX) |
| ■ | [24] | Pascal Bercher, Daniel Höller, Susanne Biundo, and Ron Alford: Proceedings of the 1st ICAPS Workshop on Hierarchical Planning. 2018 (PDF, BibTeX) |
| ■ | [23] | Daniel Höller, Pascal Bercher, Gregor Behnke, and Susanne Biundo: HTN Plan Repair Using Unmodified Planning Systems. Proceedings of the 1st ICAPS Workshop on Hierarchical Planning (HPlan), 2018: 26–30 (PDF, BibTeX) |
| ■ | [22] | Gregor Behnke, Daniel Höller, and Susanne Biundo: Tracking Branches in Trees – A Propositional Encoding for Solving Partially-Ordered HTN Planning Problems. Proceedings of the 1st ICAPS Workshop on Hierarchical Planning (HPlan), 2018: 40–47 (PDF, BibTeX) |
| ■ | [21] | Daniel Höller, Pascal Bercher, Gregor Behnke, and Susanne Biundo: Plan and Goal Recognition as HTN Planning. Proceedings of the AAAI 2018 Workshop on Plan, Activity, and Intent Recognition (PAIR), 2018: 607–613 (PDF, BibTeX) |
| ■ | [20] | Pascal Bercher, Felix Richter, Frank Honold, Florian Nielsen, Felix Schüssel, Thomas Geier, Thilo Hörnle, Stephan Reuter, Daniel Höller, Gregor Behnke, Michael Weber, Klaus Dietmayer, Wolfgang Minker, and Susanne Biundo: A Companion-System Architecture for Realizing Individualized and Situation-Adaptive User Assistance. (Technical Report), 2018 (PDF, BibTeX) |
2017
| ■ | [19] | Gregor Behnke, Benedikt Leichtmann, Pascal Bercher, Daniel Höller, Verena Nitsch, Martin Baumann, and Susanne Biundo: Help me make a dinner! Challenges when assisting humans in action planning. Proceedings of the 2nd International Conference on Companion Technology (ICCT), 2017 (PDF, BibTeX) |
| ■ | [18] | Pascal Bercher, Gregor Behnke, Daniel Höller, and Susanne Biundo: An Admissible HTN Planning Heuristic. Proceedings of the 27th International Joint Conference on Artificial Intelligence (IJCAI), 2017: 480–488 (PDF, BibTeX) |
| ■ | [17] | Gregor Behnke, Daniel Höller, and Susanne Biundo: This is a solution! (... but is it though?) – Verifying solutions of hierarchical planning problems. Proceedings of the 27th International Conference on Automated Planning and Scheduling (ICAPS), 2017: 20–28 (PDF, BibTeX) |
| ■ | [16] | Pascal Bercher, Daniel Höller, Gregor Behnke, and Susanne Biundo: User-Centered Planning. Companion Technology – A Paradigm Shift in Human-Technology Interaction 2017: 79–100 (PDF, BibTeX) |
| ■ | [15] | Pascal Bercher, Felix Richter, Thilo Hörnle, Thomas Geier, Daniel Höller, Gregor Behnke, Florian Nielsen, Frank Honold, Felix Schüssel, Stephan Reuter, Wolfgang Minker, Michael Weber, Klaus Dietmayer, and Susanne Biundo: Advanced User Assistance for Setting Up a Home Theater. Companion Technology – A Paradigm Shift in Human-Technology Interaction 2017: 485–491 (PDF, BibTeX) |
2016
| ■ | [14] | Susanne Biundo, Daniel Höller, and Pascal Bercher: Künstliche Intelligenz – Special Issue on Companion Technologies. Künstliche Intelligenz 30 (2016) (PDF, BibTeX) |
| ■ | [13] | Pascal Bercher and Daniel Höller: Interview with David E. Smith. Künstliche Intelligenz 30: 101-105 (2016) (PDF, BibTeX) |
| ■ | [12] | Susanne Biundo, Daniel Höller, Bernd Schattenberg, and Pascal Bercher: Companion-Technology: An Overview. Künstliche Intelligenz 30: 11-20 (2016) (PDF, BibTeX) |
| ■ | [11] | Gregor Behnke, Daniel Höller, Pascal Bercher, and Susanne Biundo: Change the Plan – How hard can that be?. Proceedings of the 26th International Conference on Automated Planning and Scheduling (ICAPS), 2016: 38-46 (PDF, BibTeX) |
| ■ | [10] | Daniel Höller, Gregor Behnke, Pascal Bercher, and Susanne Biundo: Assessing the Expressivity of Planning Formalisms through the Comparison to Formal Languages. Proceedings of the 26th International Conference on Automated Planning and Scheduling (ICAPS), 2016: 158-165 (PDF, BibTeX) |
| ■ | [9] | Ron Alford, Gregor Behnke, Daniel Höller, Pascal Bercher, Susanne Biundo, and David Aha: Bound to Plan: Exploiting Classical Heuristics via Automatic Translations of Tail-Recursive HTN Problems. Proceedings of the 26th International Conference on Automated Planning and Scheduling (ICAPS), 2016: 20-28 (PDF, BibTeX) |
| ■ | [8] | Pascal Bercher, Daniel Höller, Gregor Behnke, and Susanne Biundo: More than a Name? On Implications of Preconditions and Effects of Compound HTN Planning Tasks. Proceedings of the 22nd European Conference on Artificial Intelligence (ECAI), 2016: 225-233 (PDF, BibTeX) |
2015
| ■ | [7] | Pascal Bercher, Daniel Höller, Gregor Behnke, and Susanne Biundo: User-Centered Planning – A Discussion on Planning in the Presence of Human Users. Proceedings of the 1st International Symposium on Companion Technology (ISCT), 2015: 79-82 (PDF, BibTeX) |
| ■ | [6] | Gregor Behnke, Daniel Höller, and Susanne Biundo: On the Complexity of HTN Plan Verification and its Implications for Plan Recognition. Proceedings of the 25th International Conference on Automated Planning and Scheduling (ICAPS), 2015: 25-33 (PDF, BibTeX) |
| ■ | [5] | Pascal Bercher, Felix Richter, Thilo Hörnle, Thomas Geier, Daniel Höller, Gregor Behnke, Florian Nothdurft, Frank Honold, Wolfgang Minker, Michael Weber, and Susanne Biundo: A Planning-based Assistance System for Setting Up a Home Theater. Proceedings of the 29th AAAI Conference on Artificial Intelligence (AAAI), 2015: 4264-4265 (PDF, BibTeX) |
2014
| ■ | [4] | Daniel Höller, Gregor Behnke, Pascal Bercher, and Susanne Biundo: Language Classification of Hierarchical Planning Problems. Proceedings of the 21st European Conference on Artificial Intelligence (ECAI), 2014: 447-452 (PDF, BibTeX) |
| ■ | [3] | Daniel Höller, Pascal Bercher, Felix Richter, Marvin Schiller, Thomas Geier, and Susanne Biundo: Finding User-friendly Linearizations of Partially Ordered Plans. Proceedings of the 28th PuK Workshop ''Planen, Scheduling und Konfigurieren, Entwerfen'' (PuK), 2014 (PDF, BibTeX) |
| ■ | [2] | Daniel Höller: Plan Recognition as Hierarchical Planning. Doctoral Consortium of the International Conference on Automated Planning and Scheduling (ICAPS DC), 2014 (BibTeX) |
2011
| ■ | [1] | Daniel Höller and Christoph Mies: Integration of a PDDL Planning Framework into the Multi-Agent Simulation System LAMPSys. Proceedings of the 26th PuK Workshop ''Planen, Scheduling und Konfigurieren, Entwerfen'' (PuK), 2011 (PDF, BibTeX) |